MIT supernumerary robotic fingers (2014)
Research on augmenting a human hand with two synchronised robotic fingers
Keep in mind 2014 research apparatus, not a currently available medical aid.
Compare up to 10 devices across categories. Keep the purpose and the source beside the numbers.
Lowest recorded store prices take priority over announced or launch prices, within the selected source market. Currencies use the dated EUR reference rates. Deposits and recurring charges are excluded from price order; missing prices stay last. Original price records remain visible.
Research on augmenting a human hand with two synchronised robotic fingers
Keep in mind 2014 research apparatus, not a currently available medical aid.
Research on controlling additional robotic limbs through leg and foot movement
Keep in mind Historical research prototype; no production or present retail availability inferred.
Published specifications and documented constraints. See the full comparison below for prices and sources.
Scroll across the table to compare every model
| Frontier & researchAdd a model | 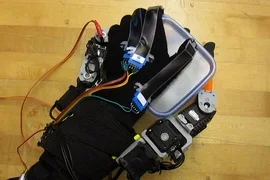 | 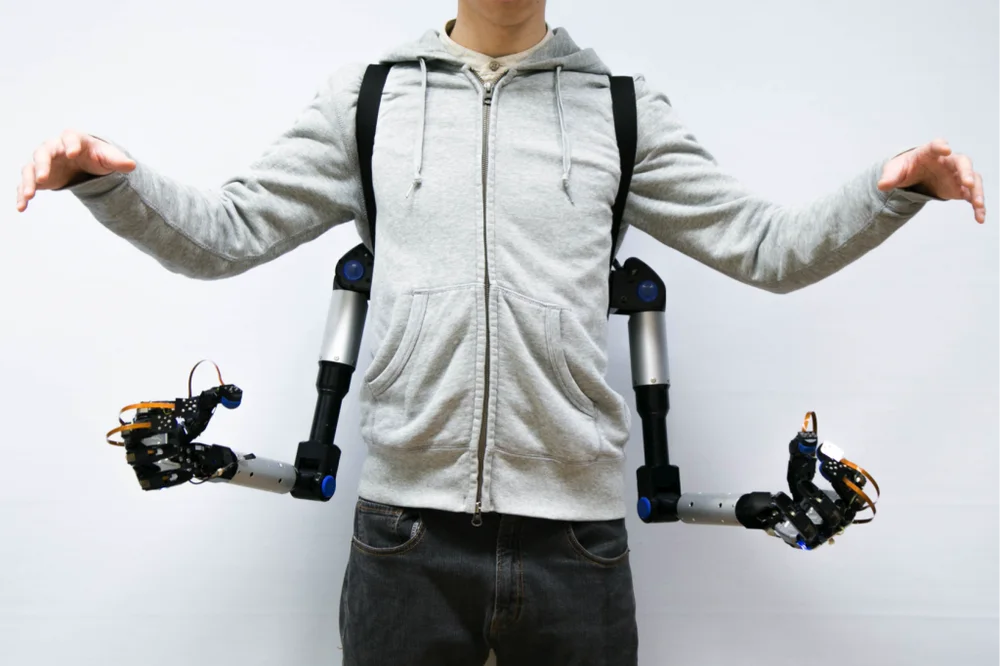 |
|---|---|---|
| Prices · all markets | Price not verified 0 offer records & sourcesNo verified price in this audit. | Price not verified 0 offer records & sourcesNo verified price in this audit. |
| Designed for | Research on augmenting a human hand with two synchronised robotic fingers ↗ | Research on controlling additional robotic limbs through leg and foot movement ↗ |
| Form factor | Wrist-mounted brace with two actuated extra fingers ↗ | Back-mounted pair of robotic arms and hands ↗ |
| Research Year | 2014 ↗ | 2017 ↗ |
| Additional Digits | Two fingers adjacent to the human thumb and little finger ↗ | Not applicable to this category |
| Actuation | Linked actuators generating grasp forces ↗ | Not applicable to this category |
| Training Sensors | Sensor glove records human finger joint positions ↗ | Not applicable to this category |
| Control | Algorithm correlates human and robotic grasp postures ↗ | Not applicable to this category |
| Coupling | Robot closes/spreads with the human hand ↗ | Not applicable to this category |
| Study Objects | Bottle, football and other grasped objects in prototype experiments ↗ | Not applicable to this category |
| Additional Limbs | Not applicable to this category | Two robot arms ↗ |
| Global Tracking | Not applicable to this category | Optical markers on knees and toes ↗ |
| Local Tracking | Not applicable to this category | Sock-type devices measure toe movement ↗ |
| Mapping | Not applicable to this category | Left/right feet mapped to respective robotic arms ↗ |
| Hand Control | Not applicable to this category | Foot/leg motion mapped into robot arms, hands and fingers ↗ |
| Project Stage | Not applicable to this category | Physical research prototype demonstrated at SIGGRAPH2017 ↗ |
| Availability | Physical MIT research prototype described in July2014. No consumer price or production release verified. | Author/laboratory research prototype; no consumer sale or public hardware purchase price verified. |
| Important context |
|
|
| Editorial pick & release | No editorial ranking recorded | No editorial ranking recorded |
| Evidence | Manufacturer source Checked 2026-10-13 | Manufacturer source Checked 2026-10-13 |
Battery claims use different conditions and are not a controlled benchmark. “Not verified” is an evidence gap, not a missing feature. Prices are dated regional snapshots. Deposits, bundles and historical launch prices are labelled. Brightness measurement methods and battery workloads vary by manufacturer.